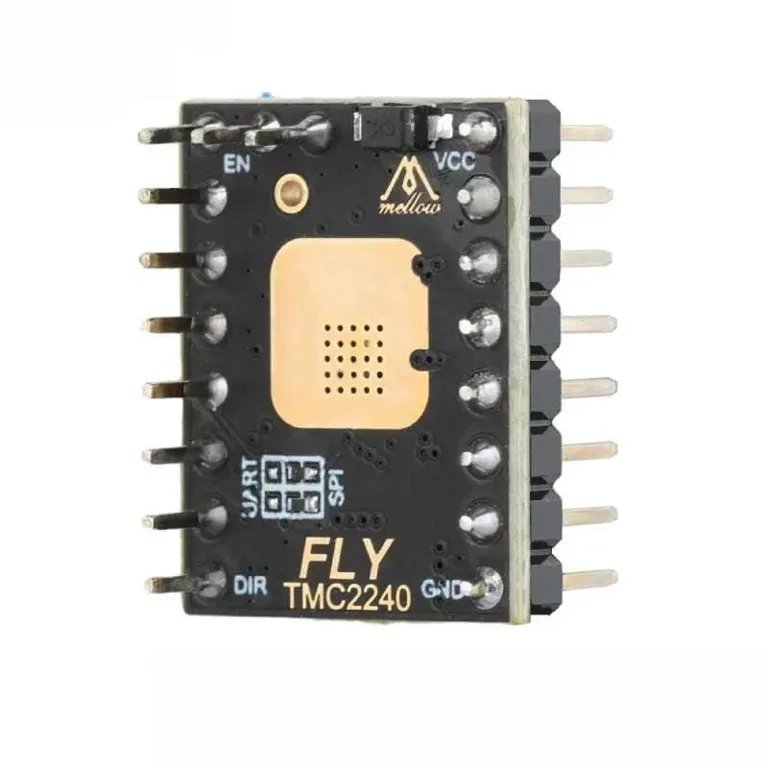
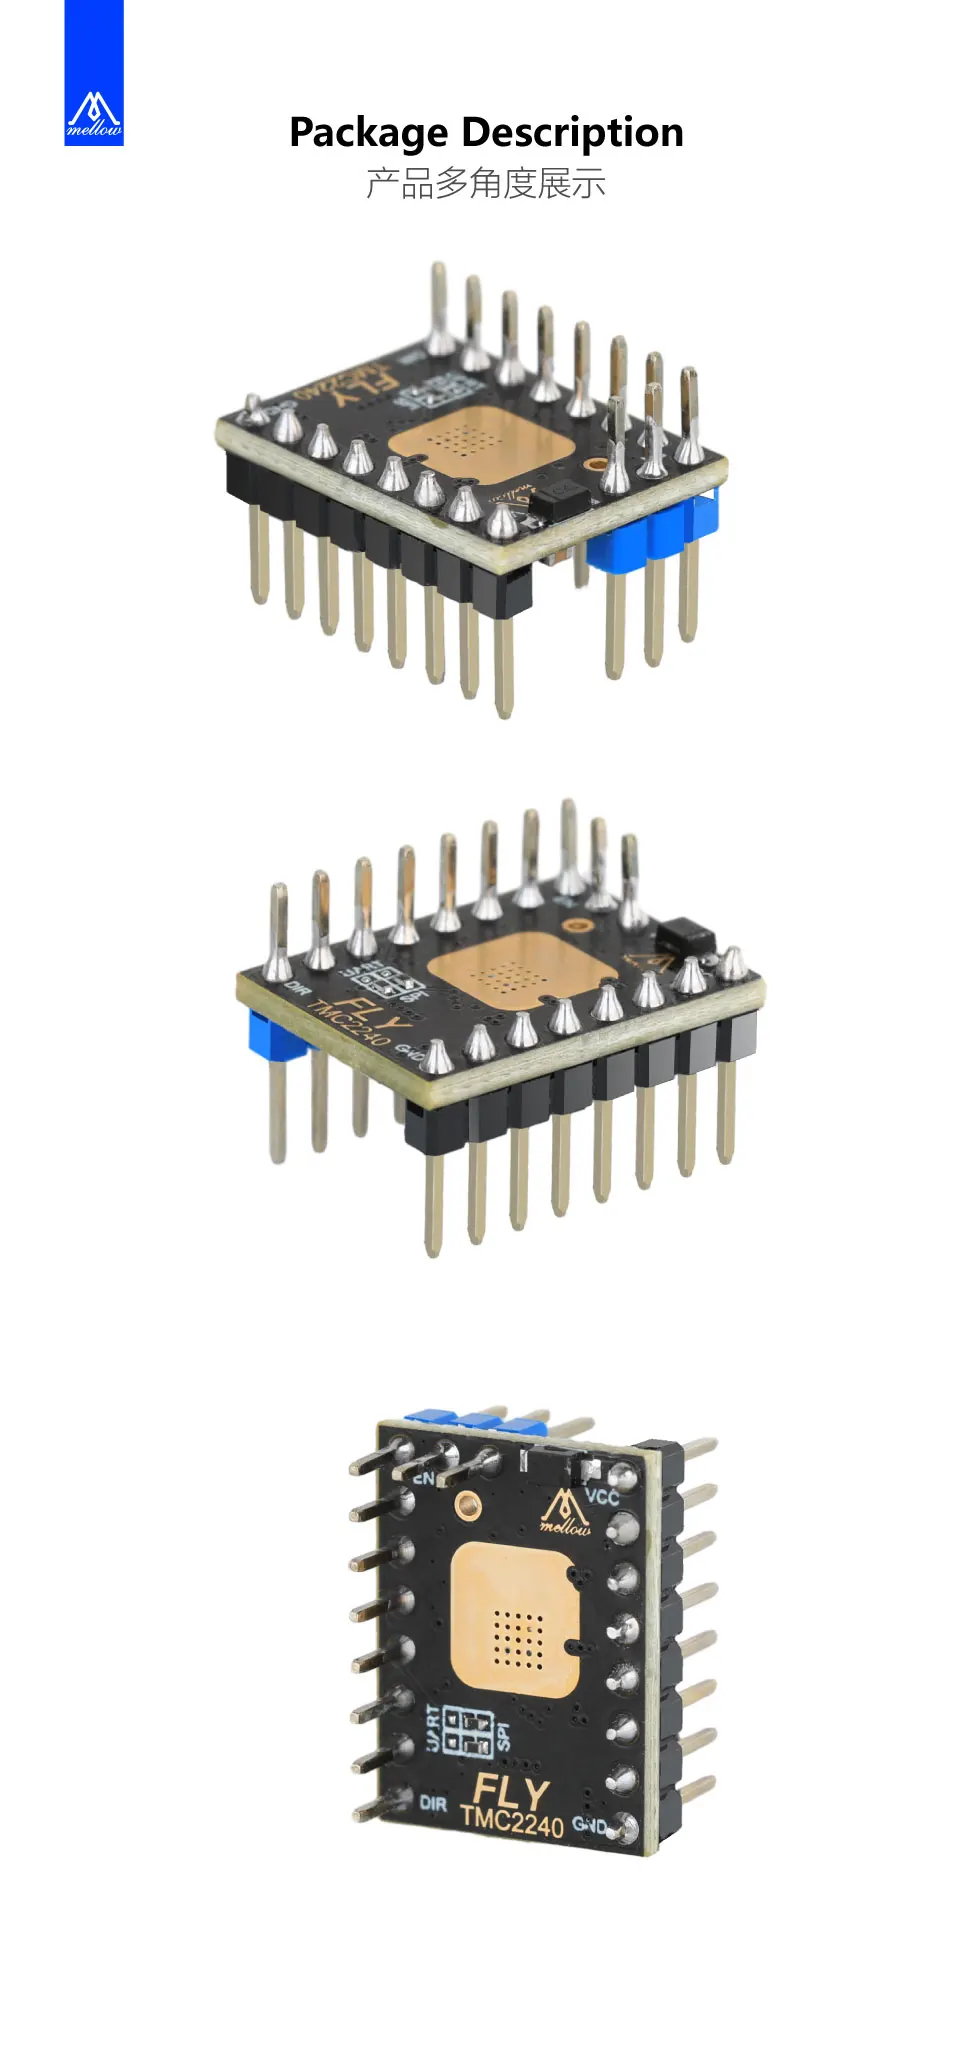
Specifications
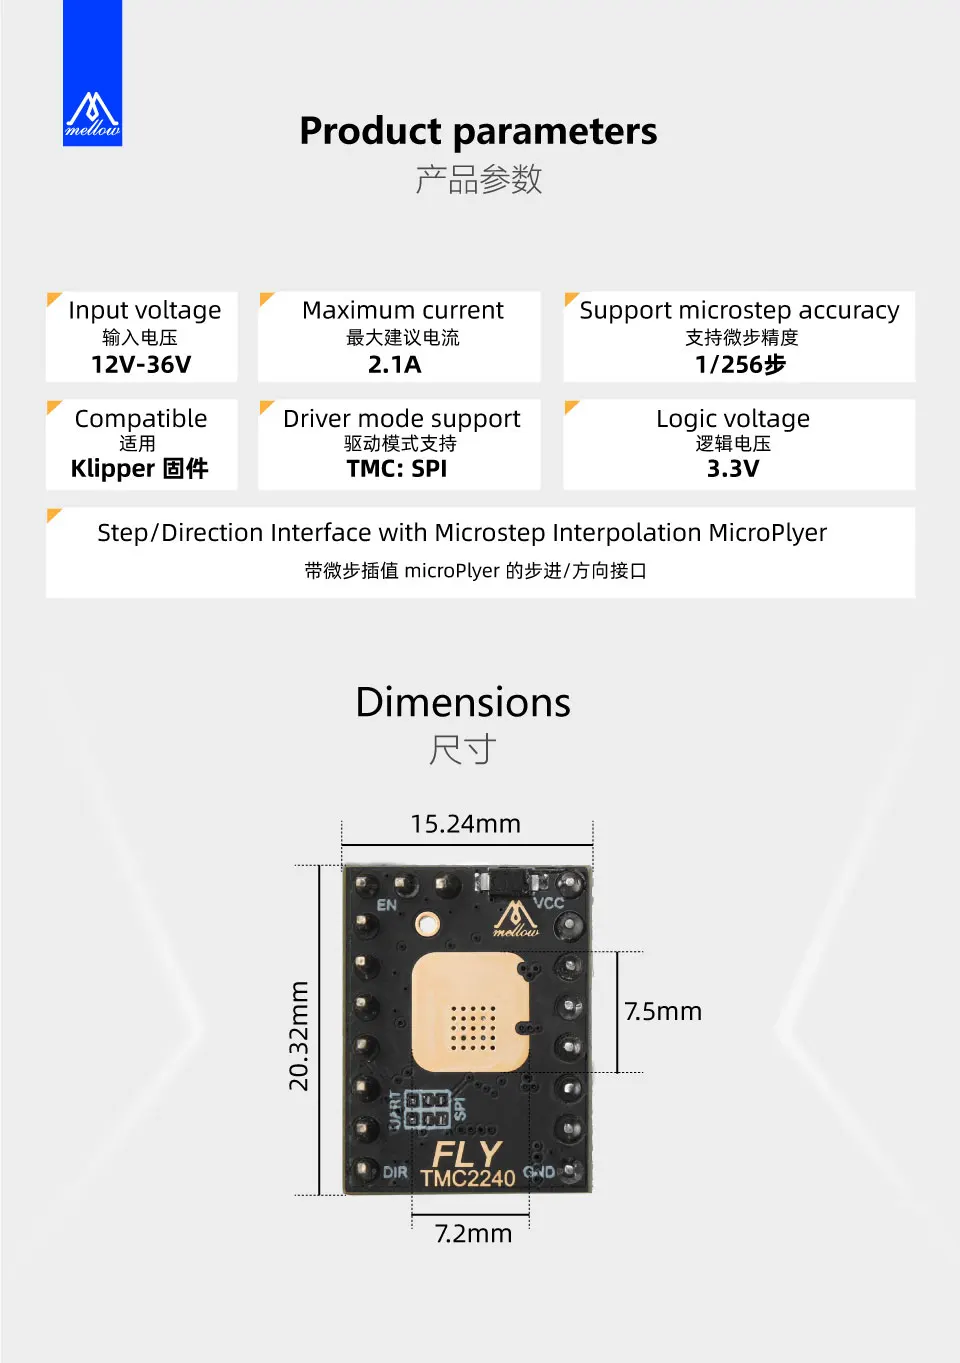
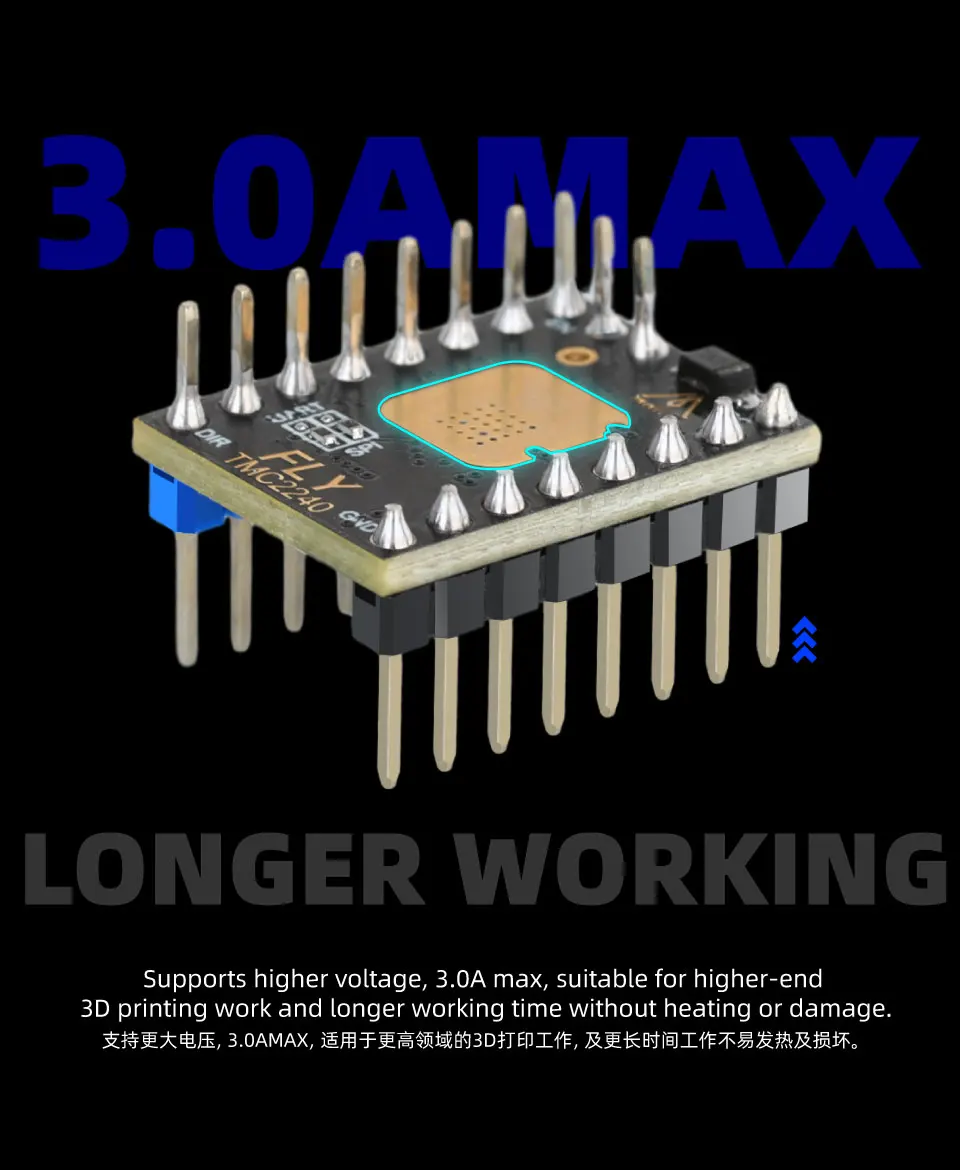
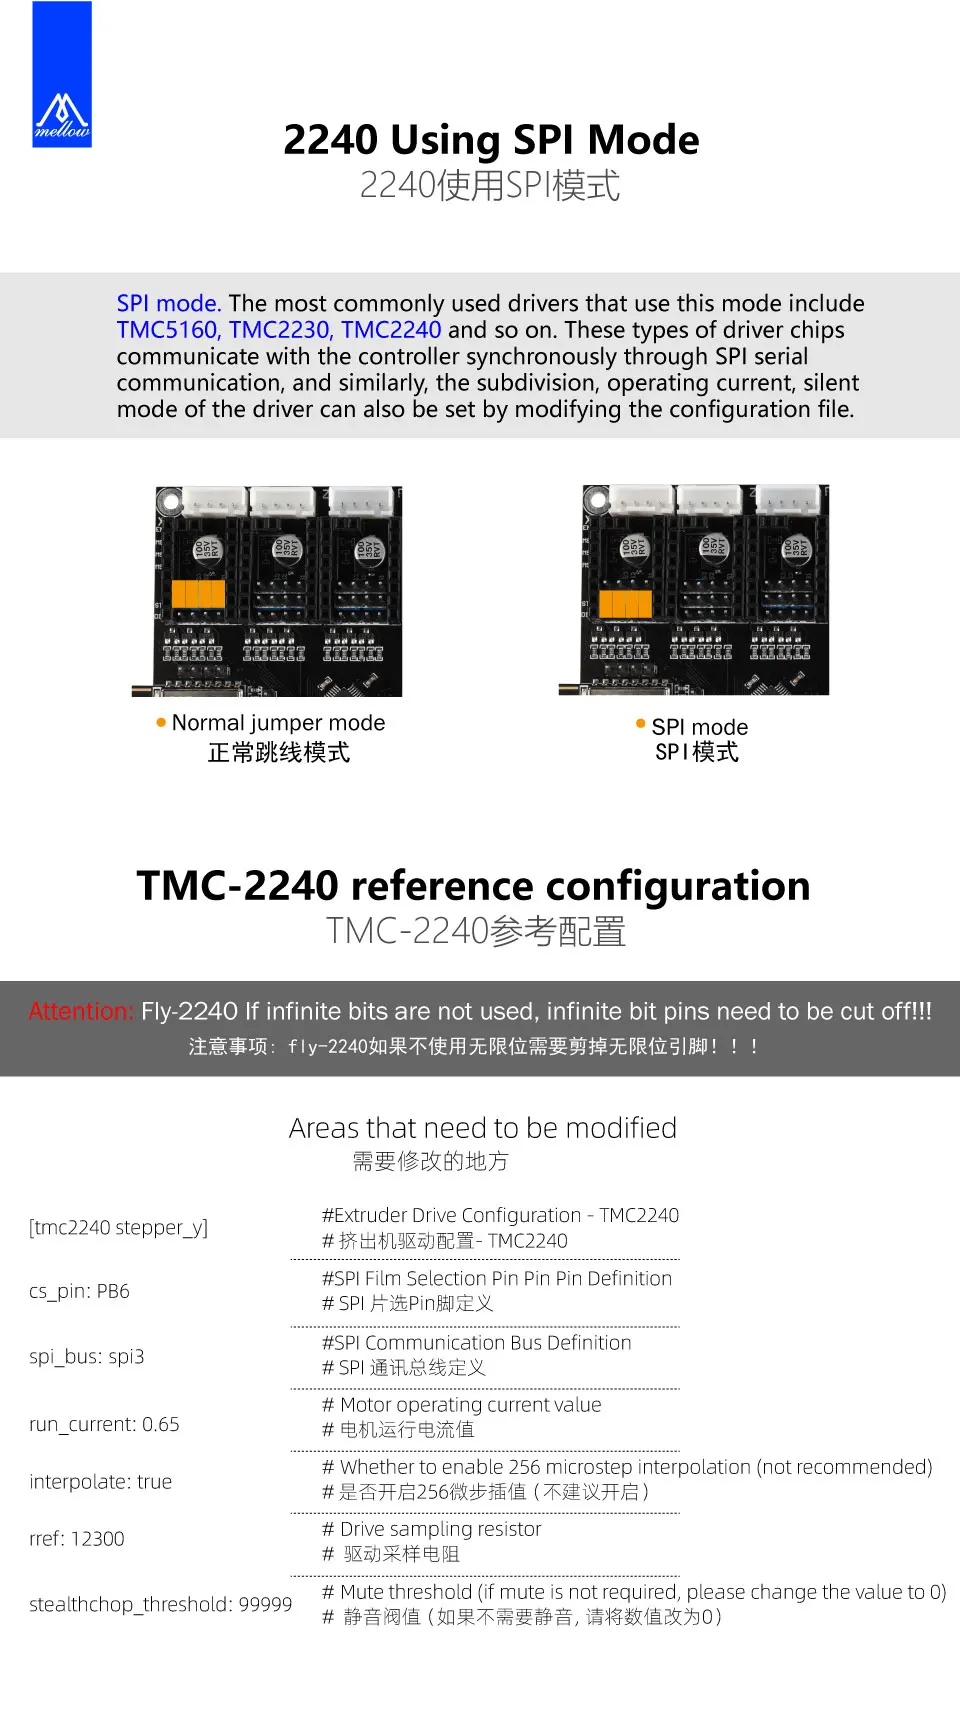
- 12–36 V, 2.1 A (3.0 A peak), up to 1/256 microstepping, 3.3 V logic. Klipper, SPI mode.
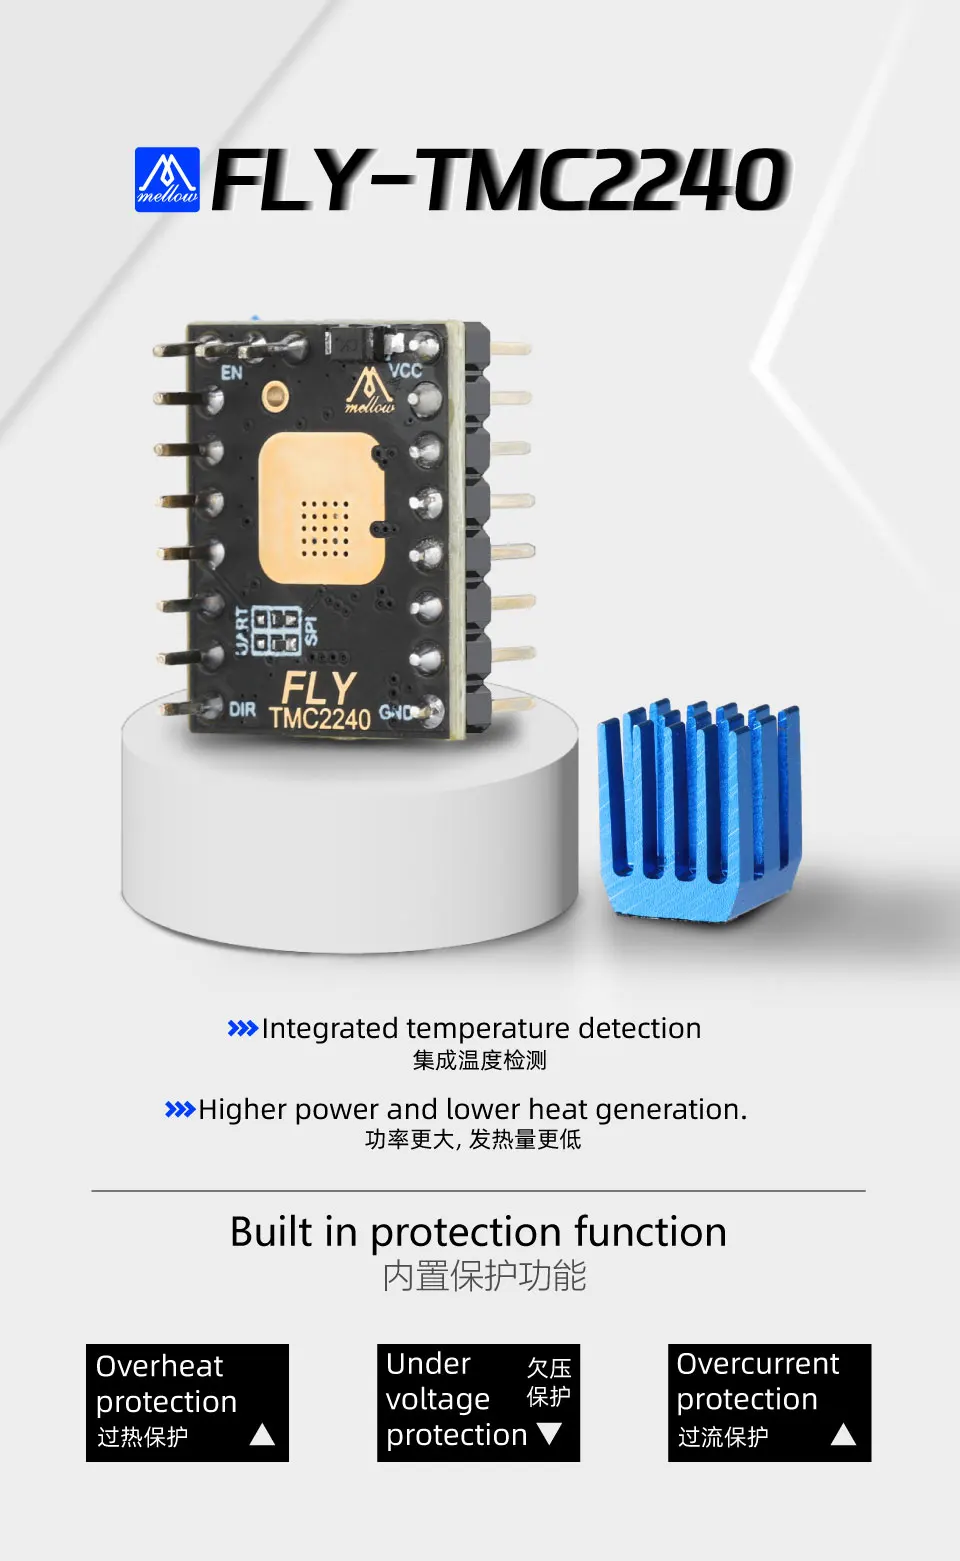
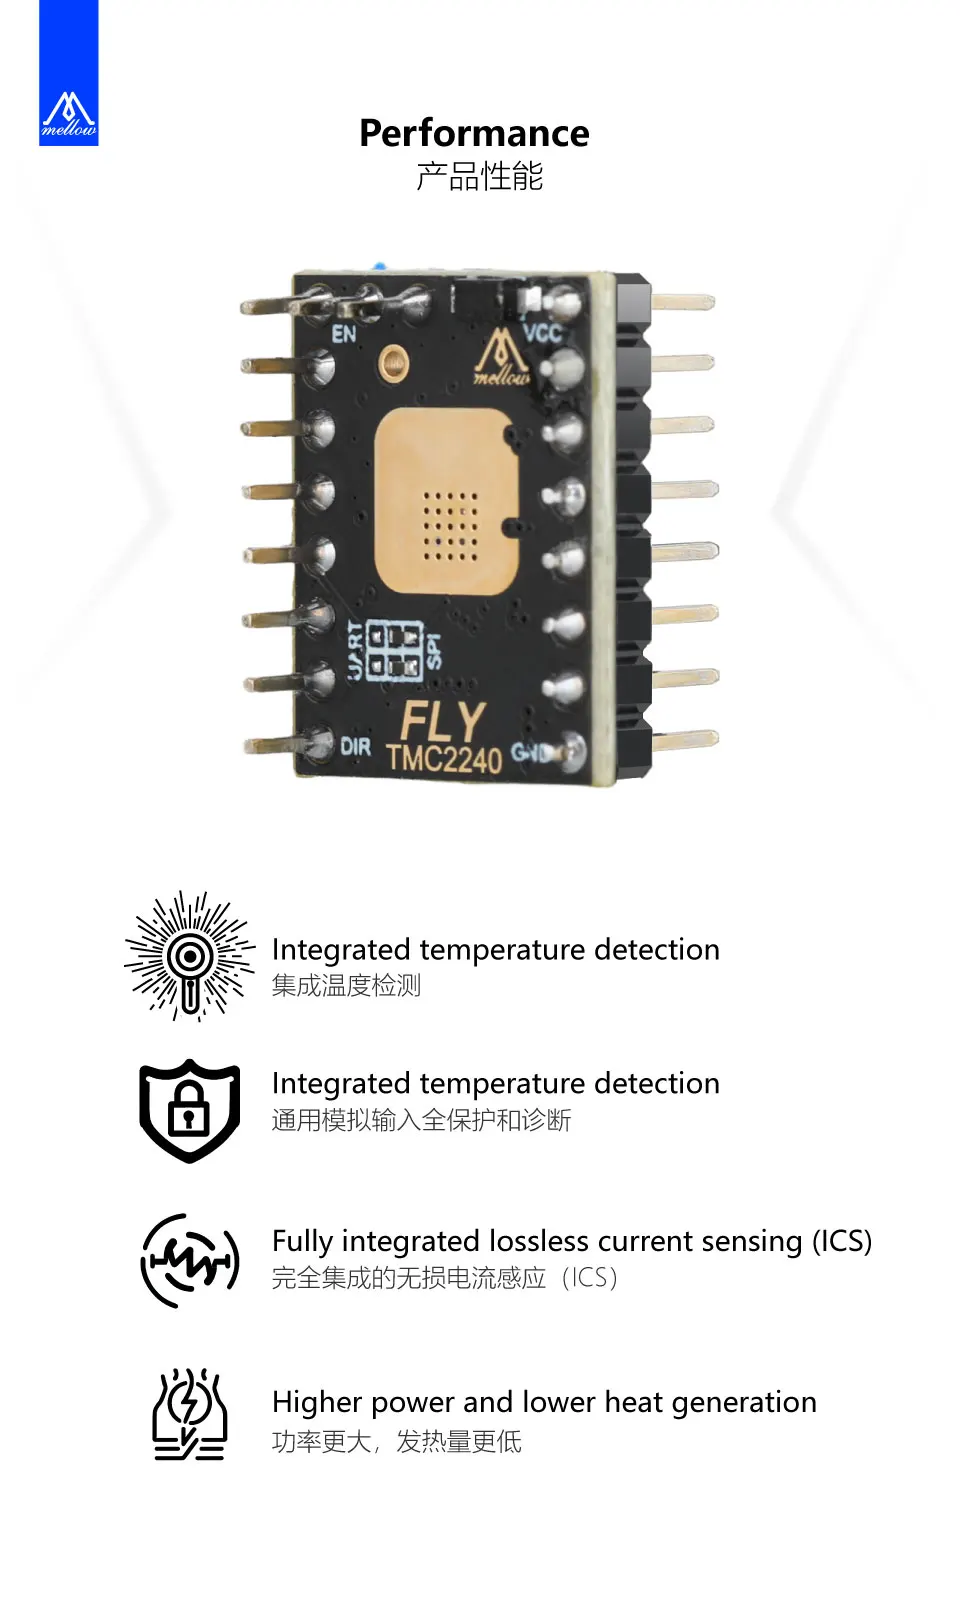
- Built-in current sensing (no sense resistors), temperature sensing, and protection against overheating, under-voltage and over-current.
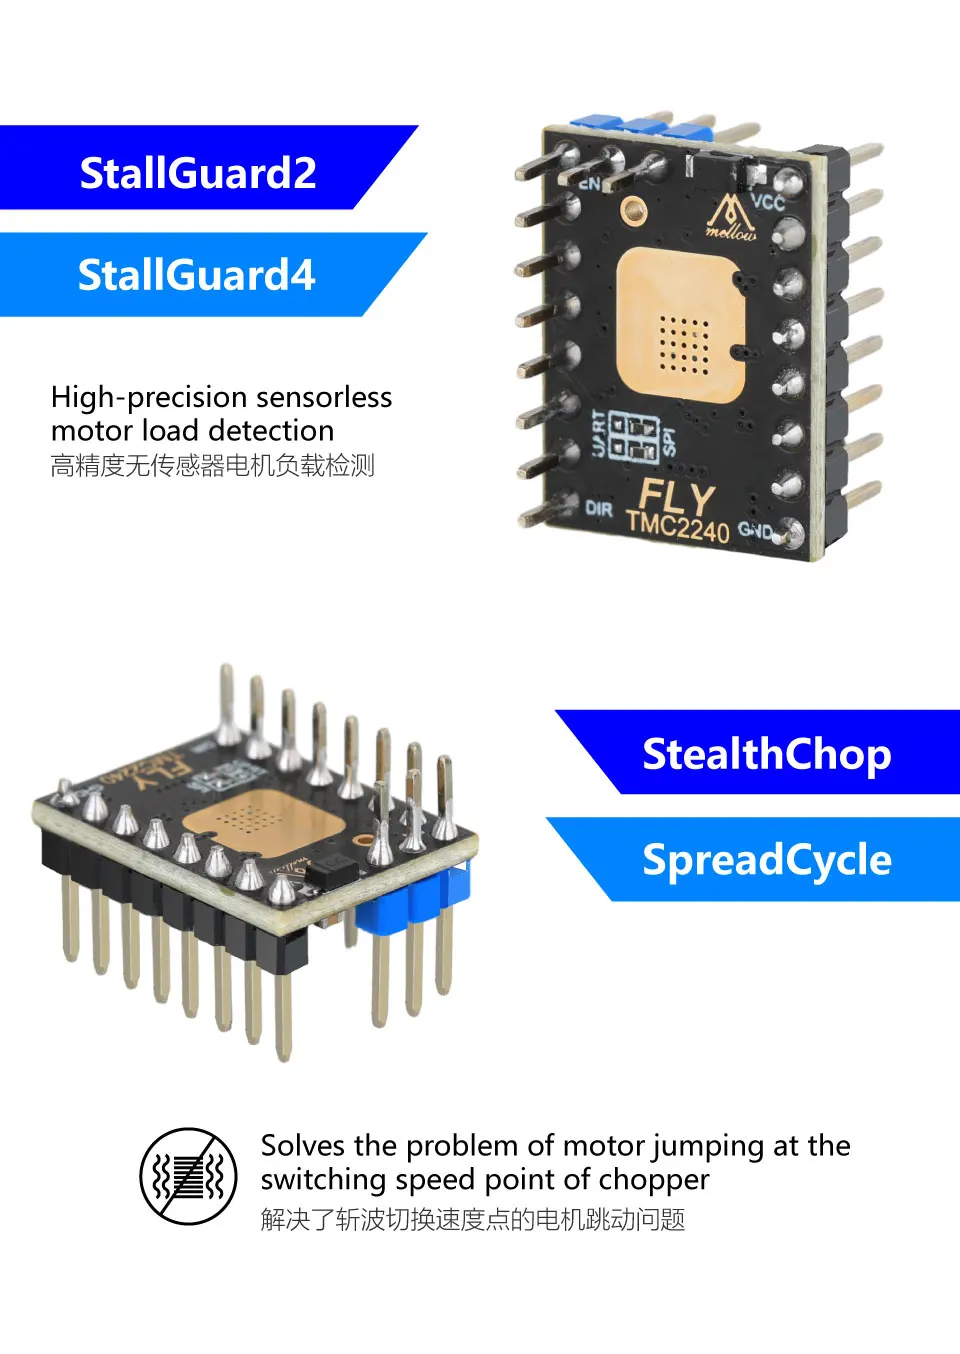
- StallGuard2/4 for sensorless homing; StealthChop for quiet running, SpreadCycle for speed.
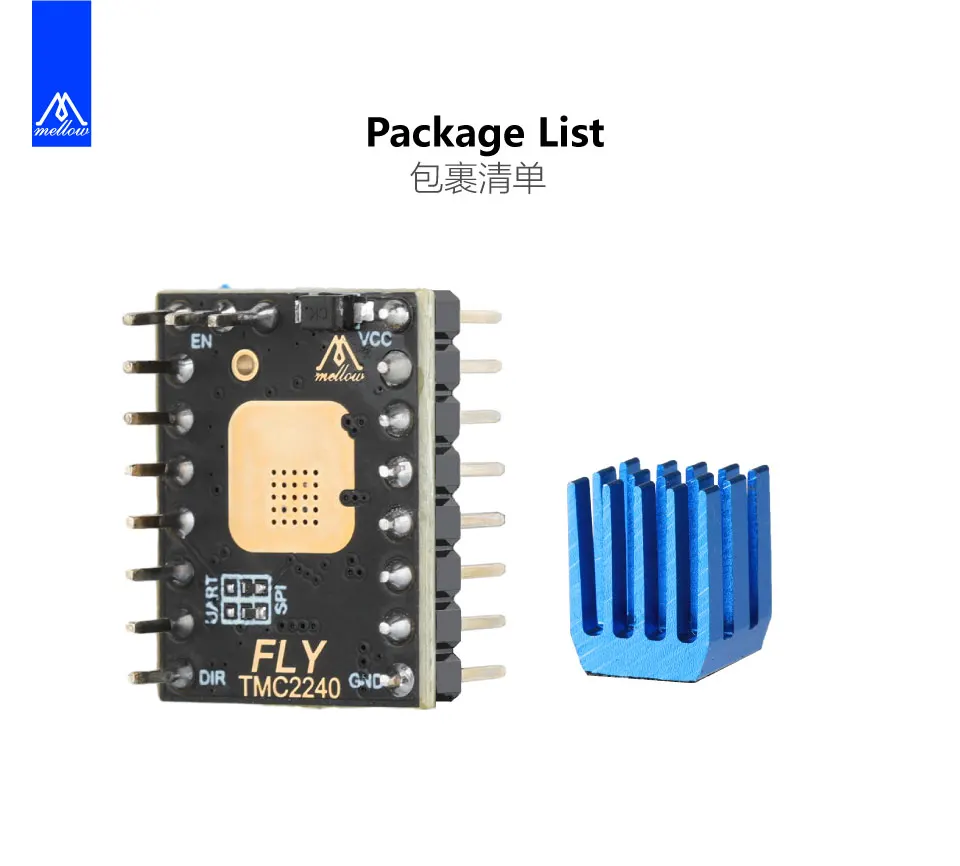
- 15.24 × 20.32 mm, heatsink included.
This version does not have a wireless homing switch. If you use our motherboard, you need to cut off the two pins on the head.
Current control method: TMC2240 uses a more advanced hybrid current control method, which means it can achieve higher step resolution at higher step angles. TMC2209 uses a traditional directional current control method.
Communication method: TMC2240 supports SPI communication, while TMC2209 does not. SPI communication is faster, can transmit data faster, so for applications that require fast response or high-speed movement, TMC2240 may be more suitable.
Optimized circuit design helps the driver work stably and achieve better heat dissipation effect.